FIELD AUTONOMY
Intelligence across terrain.
Distributed exploration, mapping and inspection where a single viewpoint is not enough.
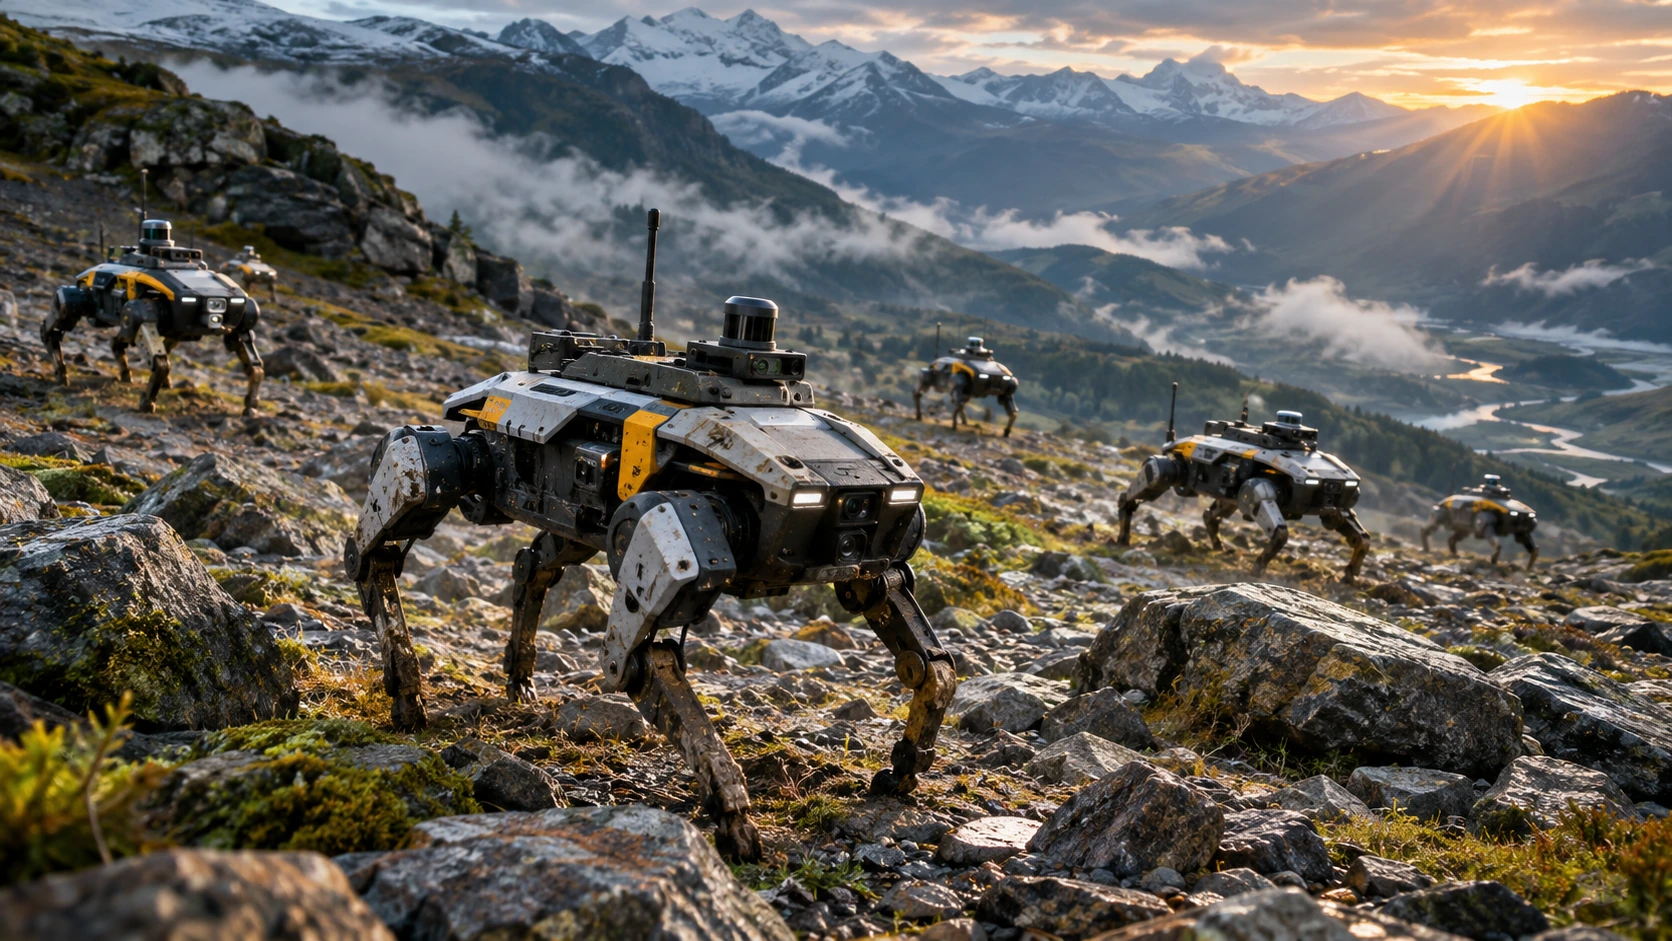 Illustrative technology scene
THE APPLICATION CASE
What the collective can change.
Ground collectives can divide terrain coverage, relay useful observations and adapt assignments as conditions change. The technical challenge is not simply adding more robots: each unit needs reliable sensing, navigation, communications, recovery and clear rules for working alongside people.
“Invisible” here describes behind-the-scenes coordination or less intrusive system operation; it is not a promise of undetectable equipment, field-proven performance or an existing InvisibleSwarm product.
THE COORDINATION CHALLENGE
Engineering that cannot be skipped.
- Terrain-aware navigation and safe obstacle avoidance
- Shared maps when localization is noisy or intermittent
- Reliable task allocation despite lost or delayed messages
WHERE VALUE MAY FORM
Commercial directions.
- Inspection across large or complex sites
- Environmental field surveys and search operations
- Research fleets and outdoor robotics platforms
THE REALITY CHECK
Precision earns trust.
Rugged terrain, weather, mobility limits, connectivity and battery management constrain real deployments; simulation success alone does not establish field reliability.